End-to-End AI Radar Signal Processing
For my master’s thesis, I extended T-FFTRadNet with a dense radial-velocity head, enabling joint detection, occupancy, and per-cell velocity prediction from range–Doppler radar data.
Loading grid…
Occupancy: every cell carries a probability that something is there. It does not say what is moving.
Motion-aware perception in one radar model.
The work added dense scene-level motion estimation to T-FFTRadNet, an existing multi-task radar perception architecture, while retaining detection and occupancy outputs.
Radar senses motion directly, but dense motion fields remain difficult.
Doppler makes radar inherently sensitive to motion, yet many learned pipelines stop at object detection or occupancy. The thesis explored whether the same bird’s-eye-view stack could also predict a dense radial-velocity field.
The model I started from did not predict velocity.
T-FFTRadNet already produced occupancy, segmentation and object detection from range–Doppler radar. The gap was motion: no velocity output, and no supervision dense enough to train one.
What I built
- A Doppler-aware velocity head, trained jointly with the existing outputs, predicting continuous radial velocity for every occupied cell on the same dense polar bird’s-eye-view grid — rather than one value per detected object, where most work stops.
- The supervision to train it. Object-level velocity labels were far too coarse, and the LiDAR available was time-of-flight with no Doppler of its own. I built DirectFlowMatch to recover dense per-point motion from consecutive scans and generate the ground truth.
- The evaluation framework around both: metric design, failure analysis, visualisation and reproducible Python/PyTorch workflows.
What was already there
The base architecture is published work, cited above. The radar dataset, the surrounding codebase and the existing prediction heads belonged to the team. The velocity head, DirectFlowMatch and the evaluation framework are mine.
Result
Occupancy-grid detection improved from 64.5% to 68.0% true-positive rate at a fixed 0.75 confidence threshold on a highway sequence. Velocity MAE 0.88 m/s.
Doppler-aware augmentation across ego speeds.
Training used Doppler-axis shifts to simulate changing ego speed while correcting the velocity targets consistently. The simulation covered ±20.48 m/s, with a maximum shift of ±256 bins and target correction Δv = shift × resolution × cos(θ).
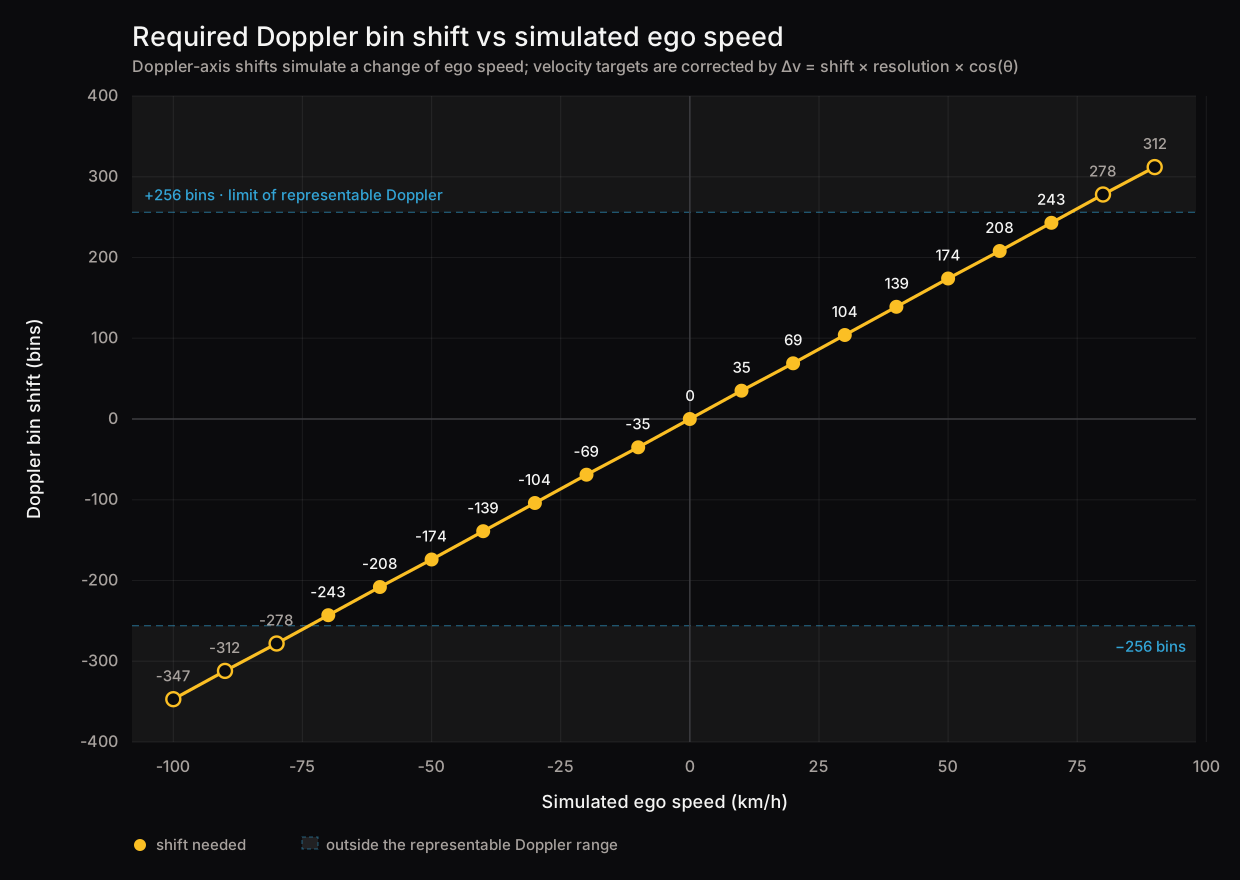
Controlled accuracy and highway occupancy improvement.
Low velocity error in a clean, structured scene
Across the evaluated airport speeds, the predicted velocity grid reached an average mean absolute error of approximately 0.21 m/s. The grids below are from the airport sequence; the MAE 0.20 m/s printed in each figure belongs to this single airport run.
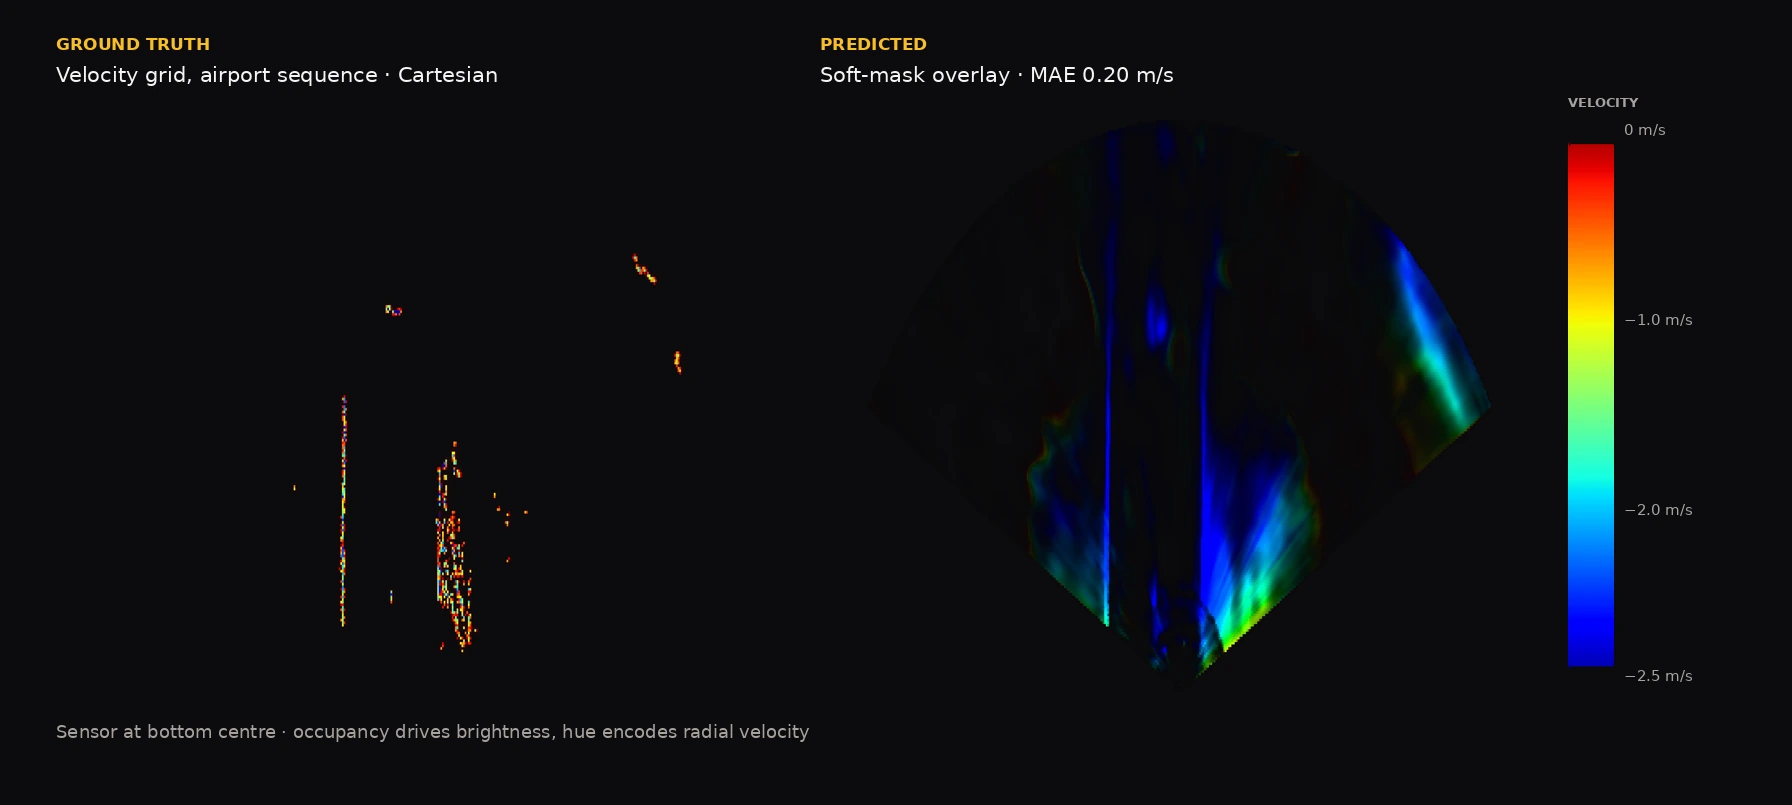
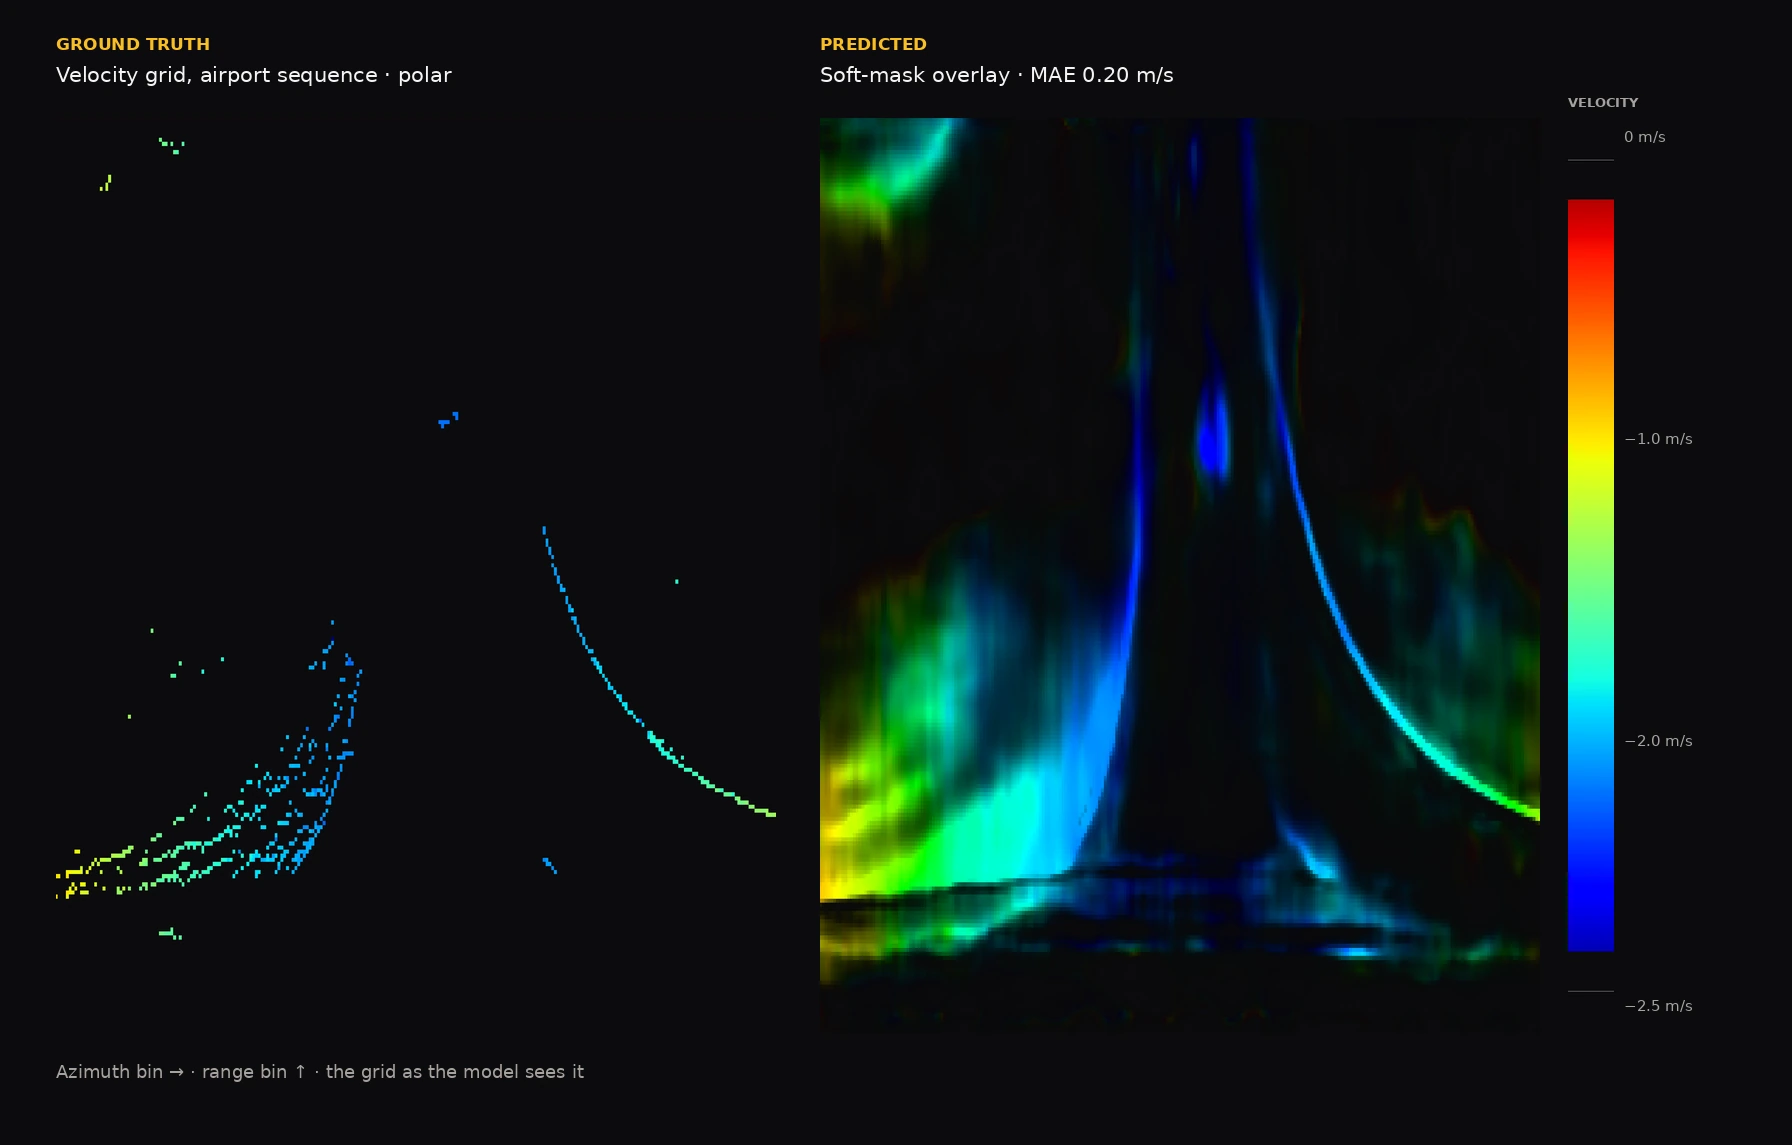
The same sequence, seen twice: on the left in world coordinates, on the right on the grid the model actually predicts on.
A harder scene with ego motion and moving traffic
The highway sequence was selected as a harder evaluation because ego motion, denser traffic, and moving vehicles create stronger relative velocities and more ambiguous scene structure than the controlled airport sequence. The grids shown here are from the highway sequence; the MAE 0.88 m/s printed in the figure belongs to this highway run, not to the airport evaluation above.
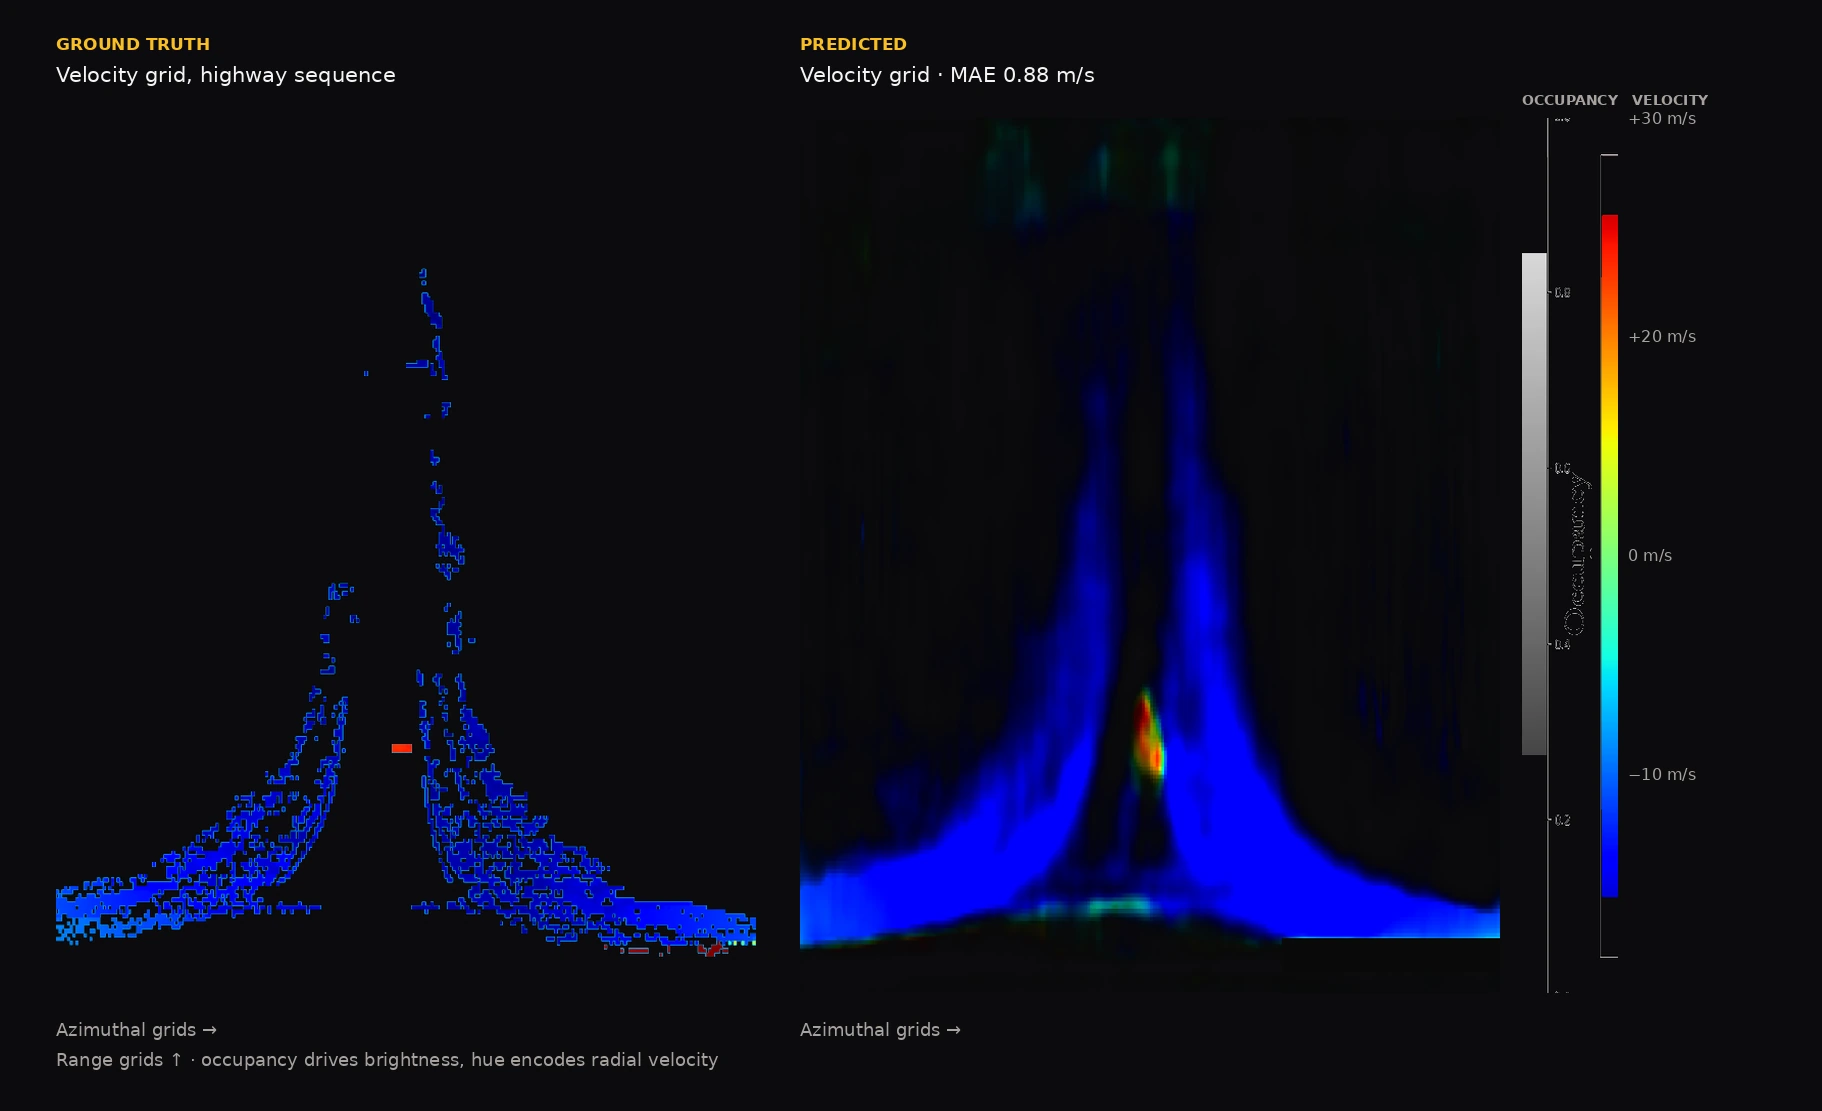
What the result demonstrates—and where it remains difficult.
The thesis demonstrates that dense radial-velocity prediction can sit inside the same bird’s-eye-view radar stack as detection and occupancy, adding scene-level motion information without a separate object-level pipeline.