01
Master's Thesis · Radar Perception
End-to-End AI Radar Signal Processing
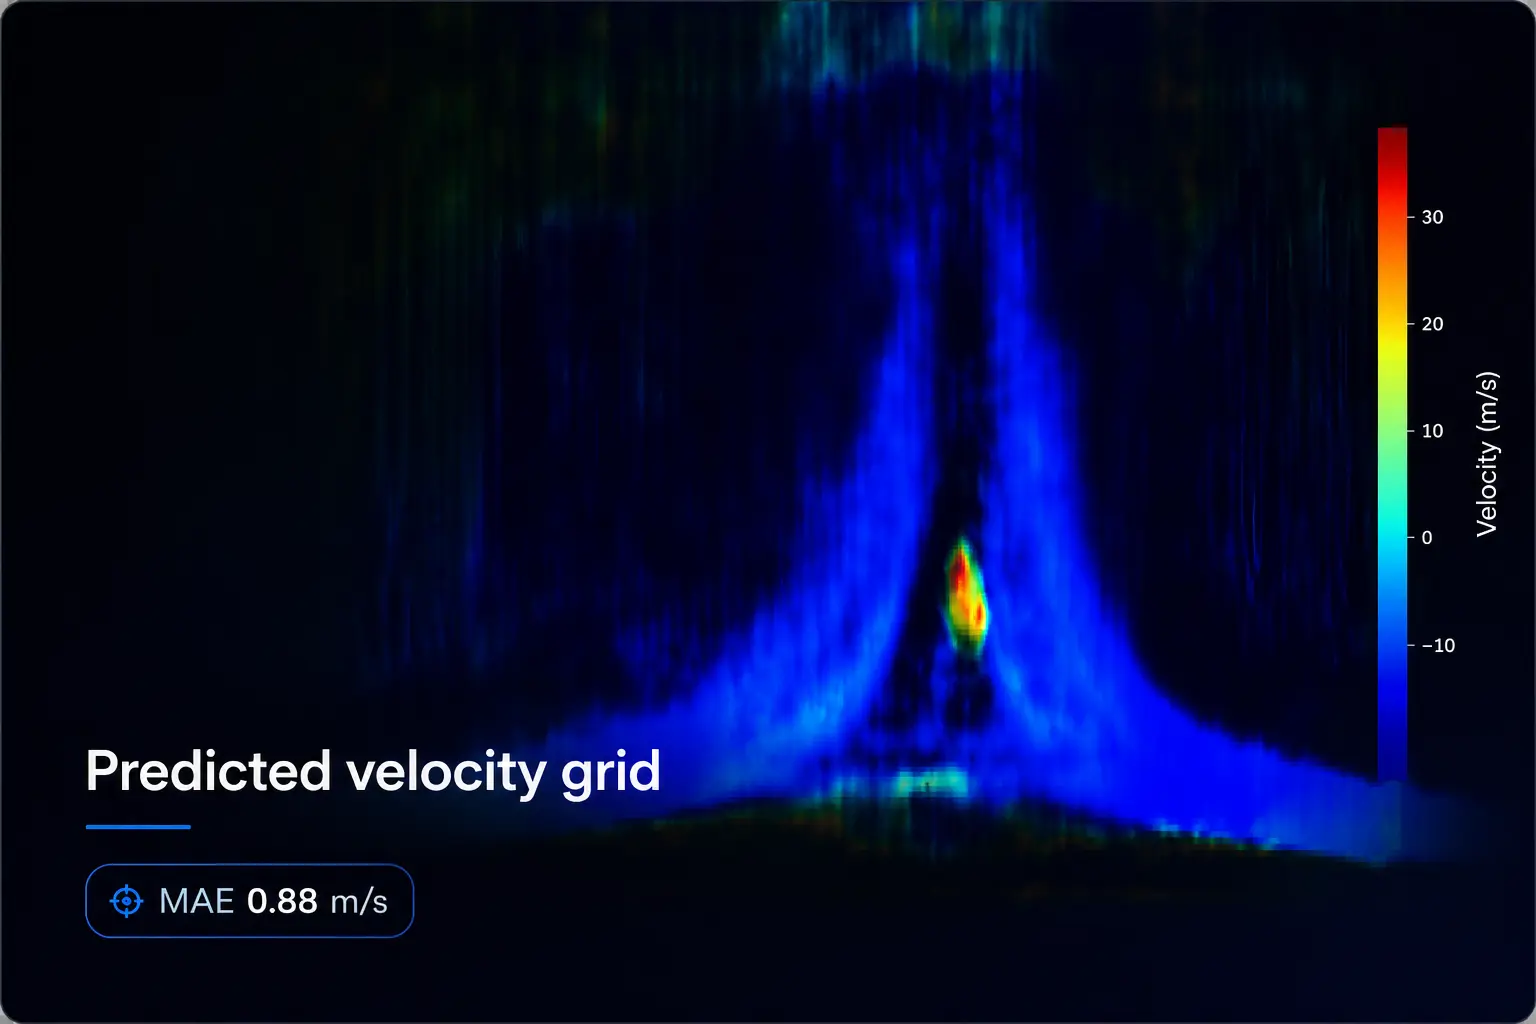
Extended T-FFTRadNet with a dense radial-velocity head for joint detection, occupancy, and per-cell velocity prediction from range–Doppler radar.
I work across radar, LiDAR, ROS/ROS2 and embedded robotics, combining learning-based perception with hands-on systems integration. I’m currently building toward connected and cooperative autonomy — trajectory planning, CAVs and V2X.
Radar · LiDAR · ROS/ROS2 · Embedded systems · Autonomous machines · Learning: CAVs & V2X
Four case studies across radar perception, LiDAR scene flow, robotics systems integration, and point-cloud evaluation—each focused on the problem, my contribution, and the outcome.
Extended T-FFTRadNet with a dense radial-velocity head for joint detection, occupancy, and per-cell velocity prediction from range–Doppler radar.
A deterministic, geometry-aware scene-flow method that estimates per-point motion from consecutive LiDAR scans without segmentation or clustering.
Implemented 4G/5G teleoperation on an ADAS-equipped prototype vehicle — remote operation between two sites — using NVIDIA Jetson, ROS control, four-camera GStreamer feedback and end-to-end reliability debugging.
Researched several preconditioning techniques for 3D point clouds to improve their compressibility, from image-based representations to structure-aware ZFP experiments.
Stanford Bunny · PNG decoded (lossless)
A synthetic scenario built for this site — a five-way junction with traffic crossing it — so moving vehicles and flow direction stay inspectable. Drag to rotate and scroll to zoom; step from the input pair through the initial matching to the complete point-level match.
Synthetic scenario · Busy urban junction
Inspect the input pair, initial matching, and complete match.
Two fingers to rotate · pinch to zoom
A focused stack grounded in the work shown across the case studies. Categories 01–05 are demonstrated in those case studies; category 06 is where I’m currently building depth.
Results from research, systems integration, and technical evaluation.
Demonstrated live to Valeo’s division CTO, regional government representatives and press.
Fixed 0.75 confidence threshold on highway evaluation.
I’m based in Erlangen, Germany, open to relocation across the EU, and interested in robotics software, perception, teleoperation, sensor-data engineering and research-oriented engineering roles — particularly where the work moves toward connected and cooperative autonomy.