01
Master's Thesis · Radar Perception
End-to-End AI Radar Signal Processing
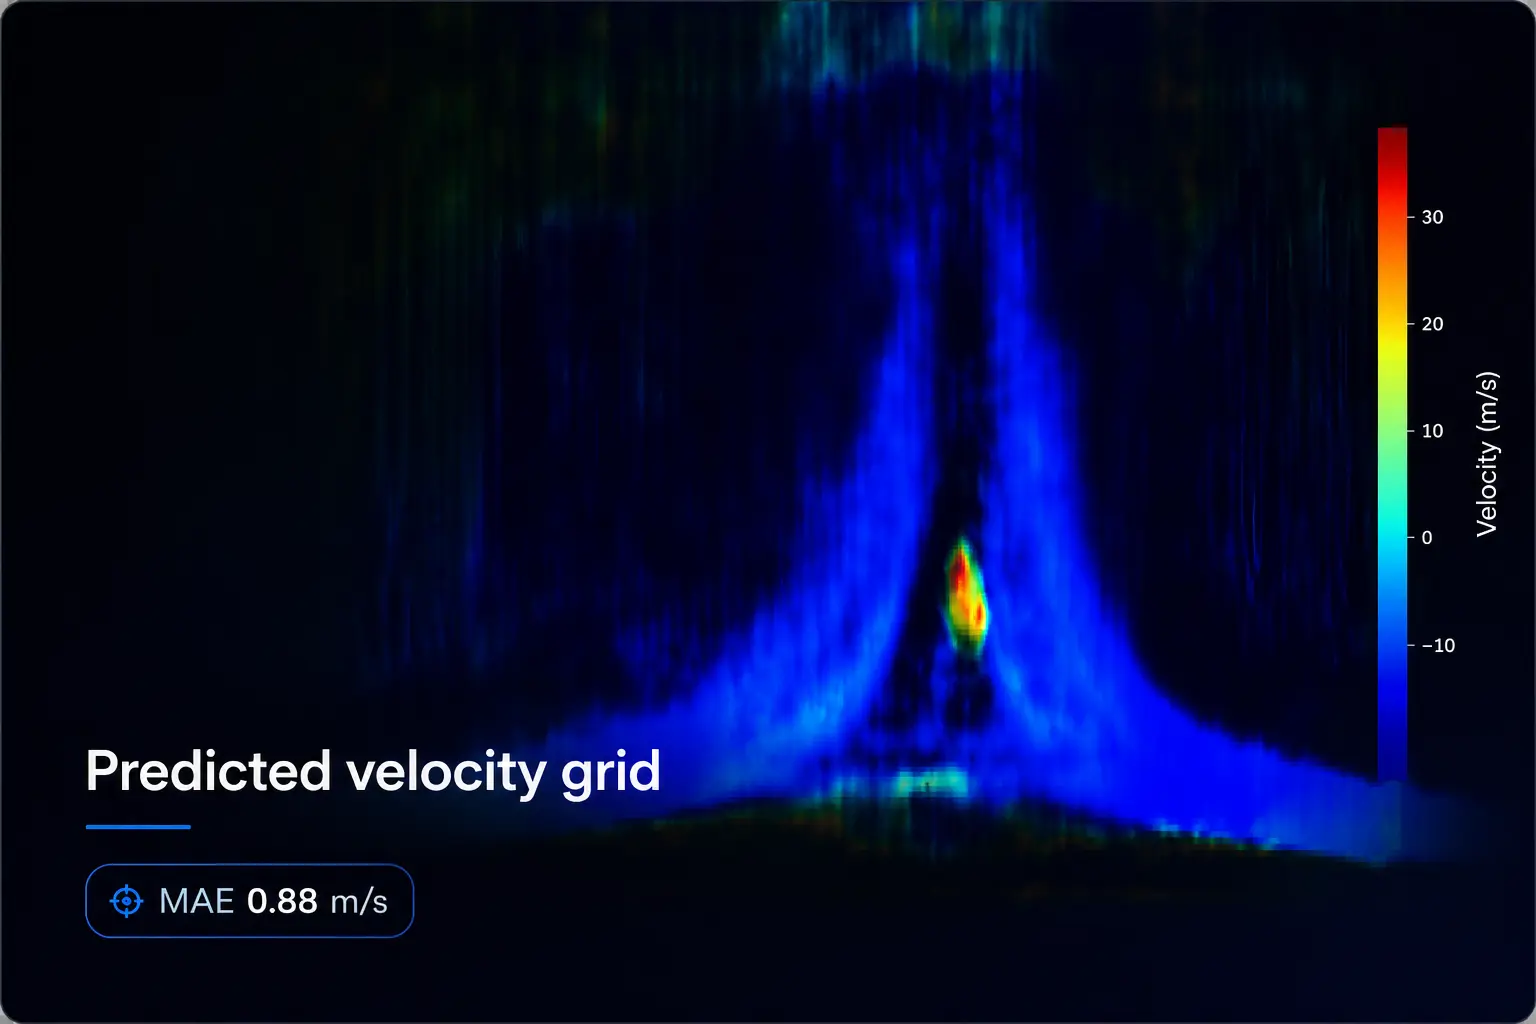
Extended T-FFTRadNet with a dense radial-velocity head for joint detection, occupancy, and per-cell velocity prediction from range–Doppler radar.
Case studies in radar and LiDAR perception, robotics systems integration, and point-cloud evaluation. Each one explains the engineering problem, my contribution, the evidence, and the limits of the result.
Extended T-FFTRadNet with a dense radial-velocity head for joint detection, occupancy, and per-cell velocity prediction from range–Doppler radar.
A deterministic, geometry-aware scene-flow method that estimates per-point motion from consecutive LiDAR scans without segmentation or clustering.
Implemented 4G/5G teleoperation on an ADAS-equipped prototype vehicle — remote operation between two sites — using NVIDIA Jetson, ROS control, four-camera GStreamer feedback and end-to-end reliability debugging.
Researched several preconditioning techniques for 3D point clouds to improve their compressibility, from image-based representations to structure-aware ZFP experiments.
Stanford Bunny · PNG decoded (lossless)